Where is the TurtleBot 4?
An ICP localizer in ROS 2, measured against OptiTrack ground truth.

- OptiTrack
- ICP estimate
- Lab map
1. Know the robot
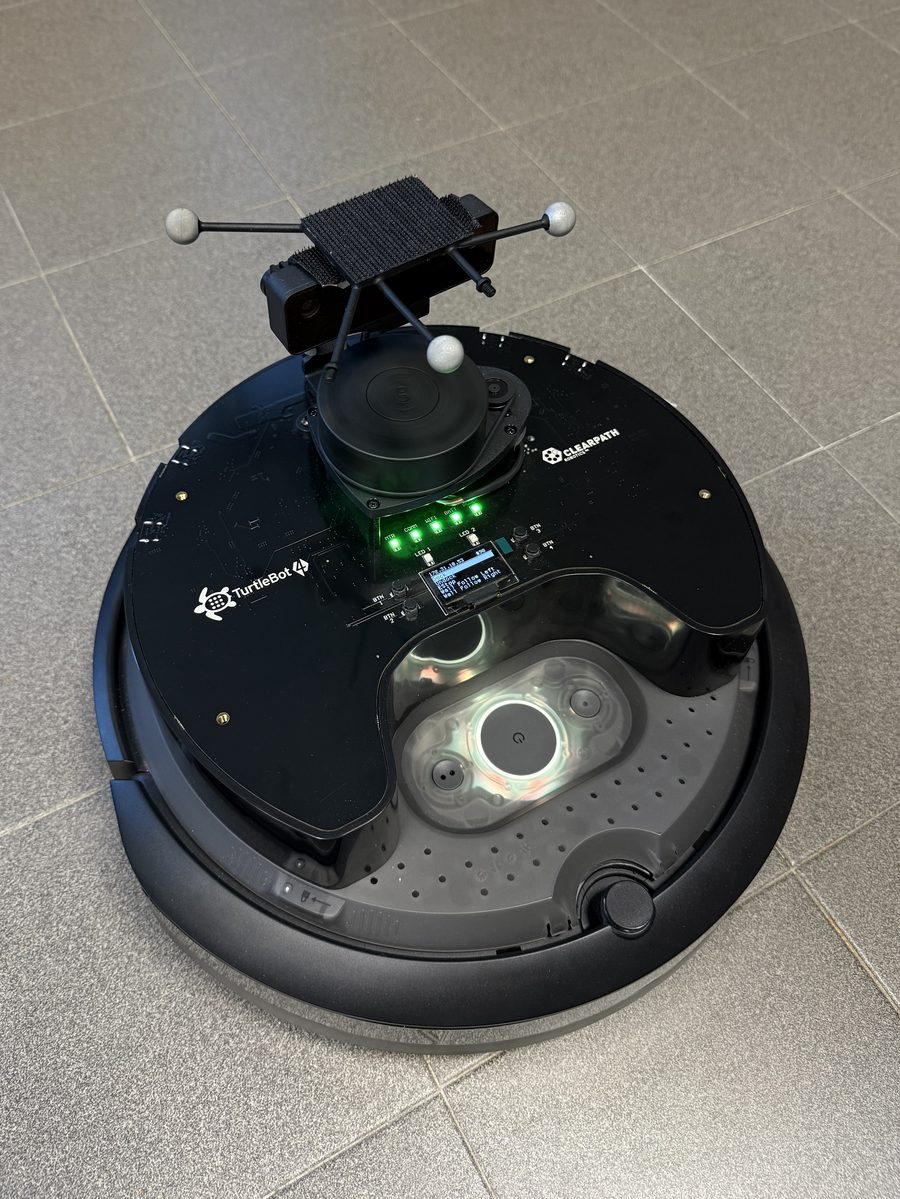
A TurtleBot 4 Standard, its LiDAR mounted 90° off the driving axis.
- Base
- iRobot Create 3
- On-board computer
- Raspberry Pi 4 Model B
- LiDAR
- RPLIDAR A1, 720 beams per turn
- Camera
- OAK-D Pro
2. Measure the laser
Where the beam meets the chassis posts the reading is missing, and at their edges it wavers.
- Mean distance, in metres
- Standard deviation
3. Lock onto the map
The icp_map node aligns every scan to a 569-point map.
- First search
- 1 m grid, 8 headings
- Correspondences
- within 0.5 m
- Iterations
- 15 while searching, 50 while tracking
- Beams kept
- beyond 0.3 m from the sensor
pcl::IterativeClosestPoint<pcl::PointXYZ, pcl::PointXYZ> icp;

pcl::registration::TransformationEstimation2D<pcl::PointXYZ, pcl::PointXYZ>::Ptr est(
    new pcl::registration::TransformationEstimation2D<pcl::PointXYZ, pcl::PointXYZ>);
icp.setTransformationEstimation(est);

icp.setInputSource(current_cloud);
icp.setInputTarget(map_cloud_);
icp.setMaxCorrespondenceDistance(0.5);
icp.setMaximumIterations(50);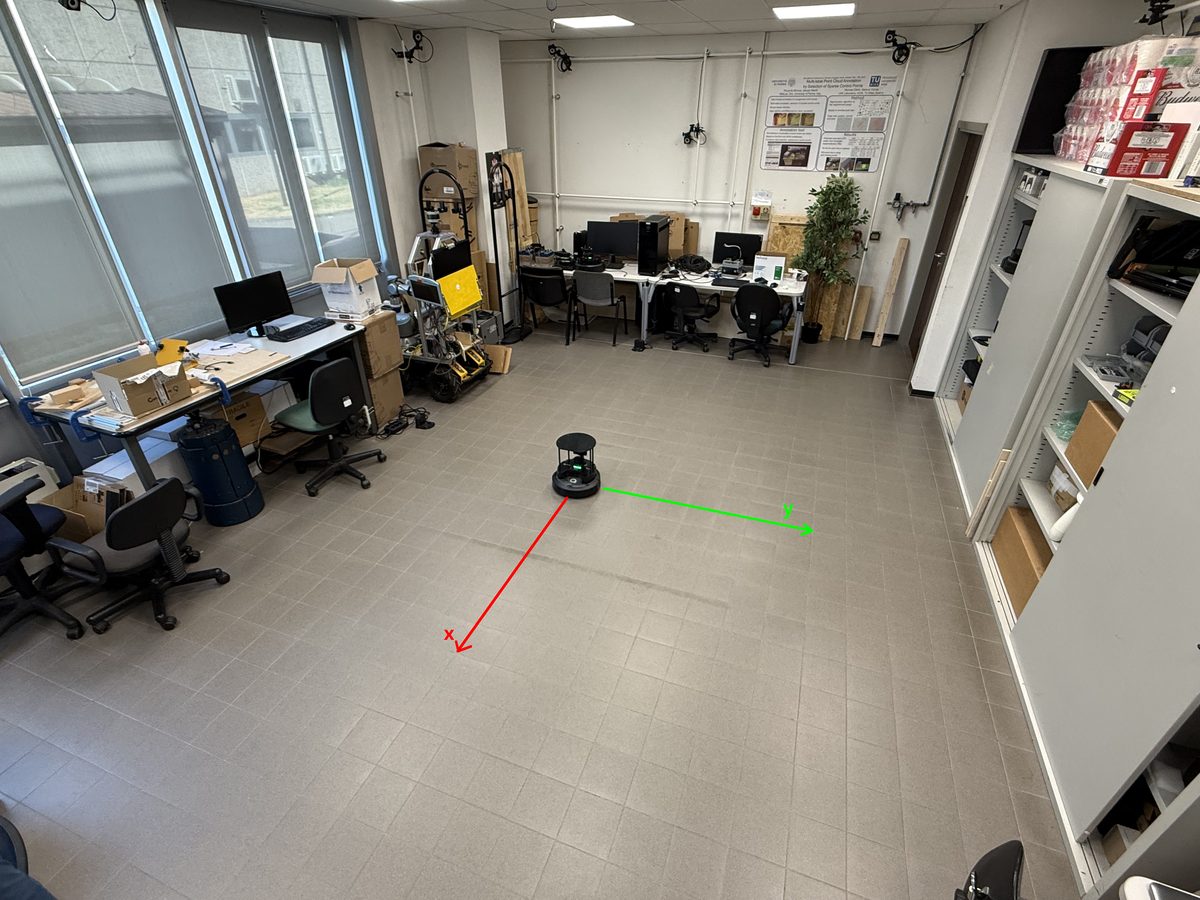
4. Ask OptiTrack for the truth
Twelve infrared cameras track the markers. Standing still, the ICP is off by about 4 cm and 1°.
5. Compare three paths
On the circle, the ICP mean error is 2.39 cm.

| Comparison | Mean error | σ |
|---|---|---|
| OptiTrack against ideal | 0.30 cm | 0.32 cm |
| ICP against ideal | 1.34 cm | 1.35 cm |
| ICP against OptiTrack | 2.39 cm | 1.74 cm |
- Ideal
- OptiTrack
- ICP
| Comparison | Mean error | σ |
|---|---|---|
| OptiTrack against ideal | 3.87 cm | 3.56 cm |
| ICP against ideal | 5.71 cm | 4.79 cm |
| ICP against OptiTrack | 3.42 cm | 3.18 cm |
| Closure, OptiTrack | 6.78 cm | |
| Closure, ICP | 8.80 cm |
| Comparison | Mean error | σ |
|---|---|---|
| OptiTrack against ideal | 5.19 cm | 3.98 cm |
| ICP against ideal | 7.87 cm | 5.34 cm |
| ICP against OptiTrack | 6.01 cm | 4.05 cm |
| Closure, OptiTrack | 10.30 cm | |
| Closure, ICP | 10.62 cm |
Eight ROS 2 nodes in C++
Open a row to read the part that matters.
icp_map
Localises the robot on the map with planar ICP262 linesThe global search that locks the first pose double step = 1.0; double test_angles[8] = {0.0, M_PI_4, M_PI_2, 3*M_PI_4, M_PI, -3*M_PI_4, -M_PI_2, -M_PI_4}; // iteriamo su tutta la superficie della stanza for (double x = min_pt.x; x <= max_pt.x; x += step) { for (double y = min_pt.y; y <= max_pt.y; y += step) { for (int i = 0; i < 8; ++i) { double cos_y = std::cos(test_angles[i]); double sin_y = std::sin(test_angles[i]); Eigen::Matrix4f guess = Eigen::Matrix4f::Identity(); guess(0, 0) = cos_y; guess(0, 1) = -sin_y; guess(1, 0) = sin_y; guess(1, 1) = cos_y; guess(0, 3) = x; guess(1, 3) = y; pcl::PointCloud<pcl::PointXYZ> temp_final; icp.setMaximumIterations(15); icp.align(temp_final, guess); if (icp.hasConverged()) { double score = icp.getFitnessScore(); if (score < best_score) { best_score = score; best_guess = guess; } } } } }laser_stat
Mean and standard deviation of every beam79 linesThe sums accumulated at every scan for (int i = 0; i < num_raggi; i++) { float distanza = msg->ranges[i]; if (std::isfinite(distanza)) { somme_[i] += distanza; somme_quadrati_[i] += (distanza * distanza); conteggi_[i]++; } }virtual_bumper
Stops the robot 0.35 m from an obstacle96 linesThe front sector and the stop threshold if (a_robot > -0.5 && a_robot < 0.5) { if (r < min_distance) { min_distance = r; } } } if (min_distance < threshold_) { cmd.linear.x = 0.0; cmd.angular.z = 0.0; } else { cmd.linear.x = speed_; cmd.angular.z = 0.0; }obstacle_avoider
Turns towards the freer side105 linesThe choice between left and right if (min_front < threshold_) { cmd.linear.x = 0.0; if (min_left > min_right) { cmd.angular.z = turnrate_; } else { cmd.angular.z = -turnrate_; } } else { cmd.linear.x = speed_; cmd.angular.z = 0.0; }quadrato_nodo
A timed 1 m square, with no feedback88 linesThe 90° turn, counted in cycles // FASE 1: GIRA DI 90 GRADI else if (fase_ == 1) { messaggio.angular.z = 0.785; contatore_++; // CURVA: 2 secondi (20 cicli) if (contatore_ >= 20) { contatore_ = 0; lati_completati_++; if (lati_completati_ >= 4) { fase_ = 2; // Ha fatto 4 lati completi } else { fase_ = 0; RCLCPP_INFO(this->get_logger(), "==> PARTENZA LATO %d", lati_completati_ + 1); } } }quadrato_odom_nodo
The same square, closed on odometry95 linesThe 1 m side measured on /odom // FASE 0: VAI DRITTO FINO A 1 METRO if (fase_ == 0) { double distance = std::sqrt(std::pow(current_x - start_x_, 2) + std::pow(current_y - start_y_, 2)); if (distance < 1.0) { cmd.linear.x = 0.15; cmd.angular.z = 0.0; } else { cmd.linear.x = 0.0; fase_ = 1; init_pose_captured_ = false; RCLCPP_INFO(this->get_logger(), "inizio curva %d ", lati_completati_ + 1); } }cerchio_nodo
A 50 cm radius circle at constant speed45 linesTwo constant speeds are enough void cerchio_robot() { geometry_msgs::msg::Twist messaggio; messaggio.linear.x = 0.2; messaggio.angular.z = 0.4; publisher_->publish(messaggio); }slalom_nodo
Alternating turns every two seconds69 linesRight and left, four cycles each // fase 0 destra if (fase_==0){ messaggio.linear.x = 0.45; messaggio.angular.z = 1.2; cont_=cont_+1; if (cont_>=4){ fase_=1; cont_=0; } }